Skip to content
CCN Maastricht
Menu

Research line

Functional whole-brain models

Classic whole-brain models are biologically grounded. They do not perform any behaviour, however. Functional whole-brain models aim to be biologically grounded and functionally competent at the same time. This means they also perform tasks.

Our framework paper sets out how to build such models.
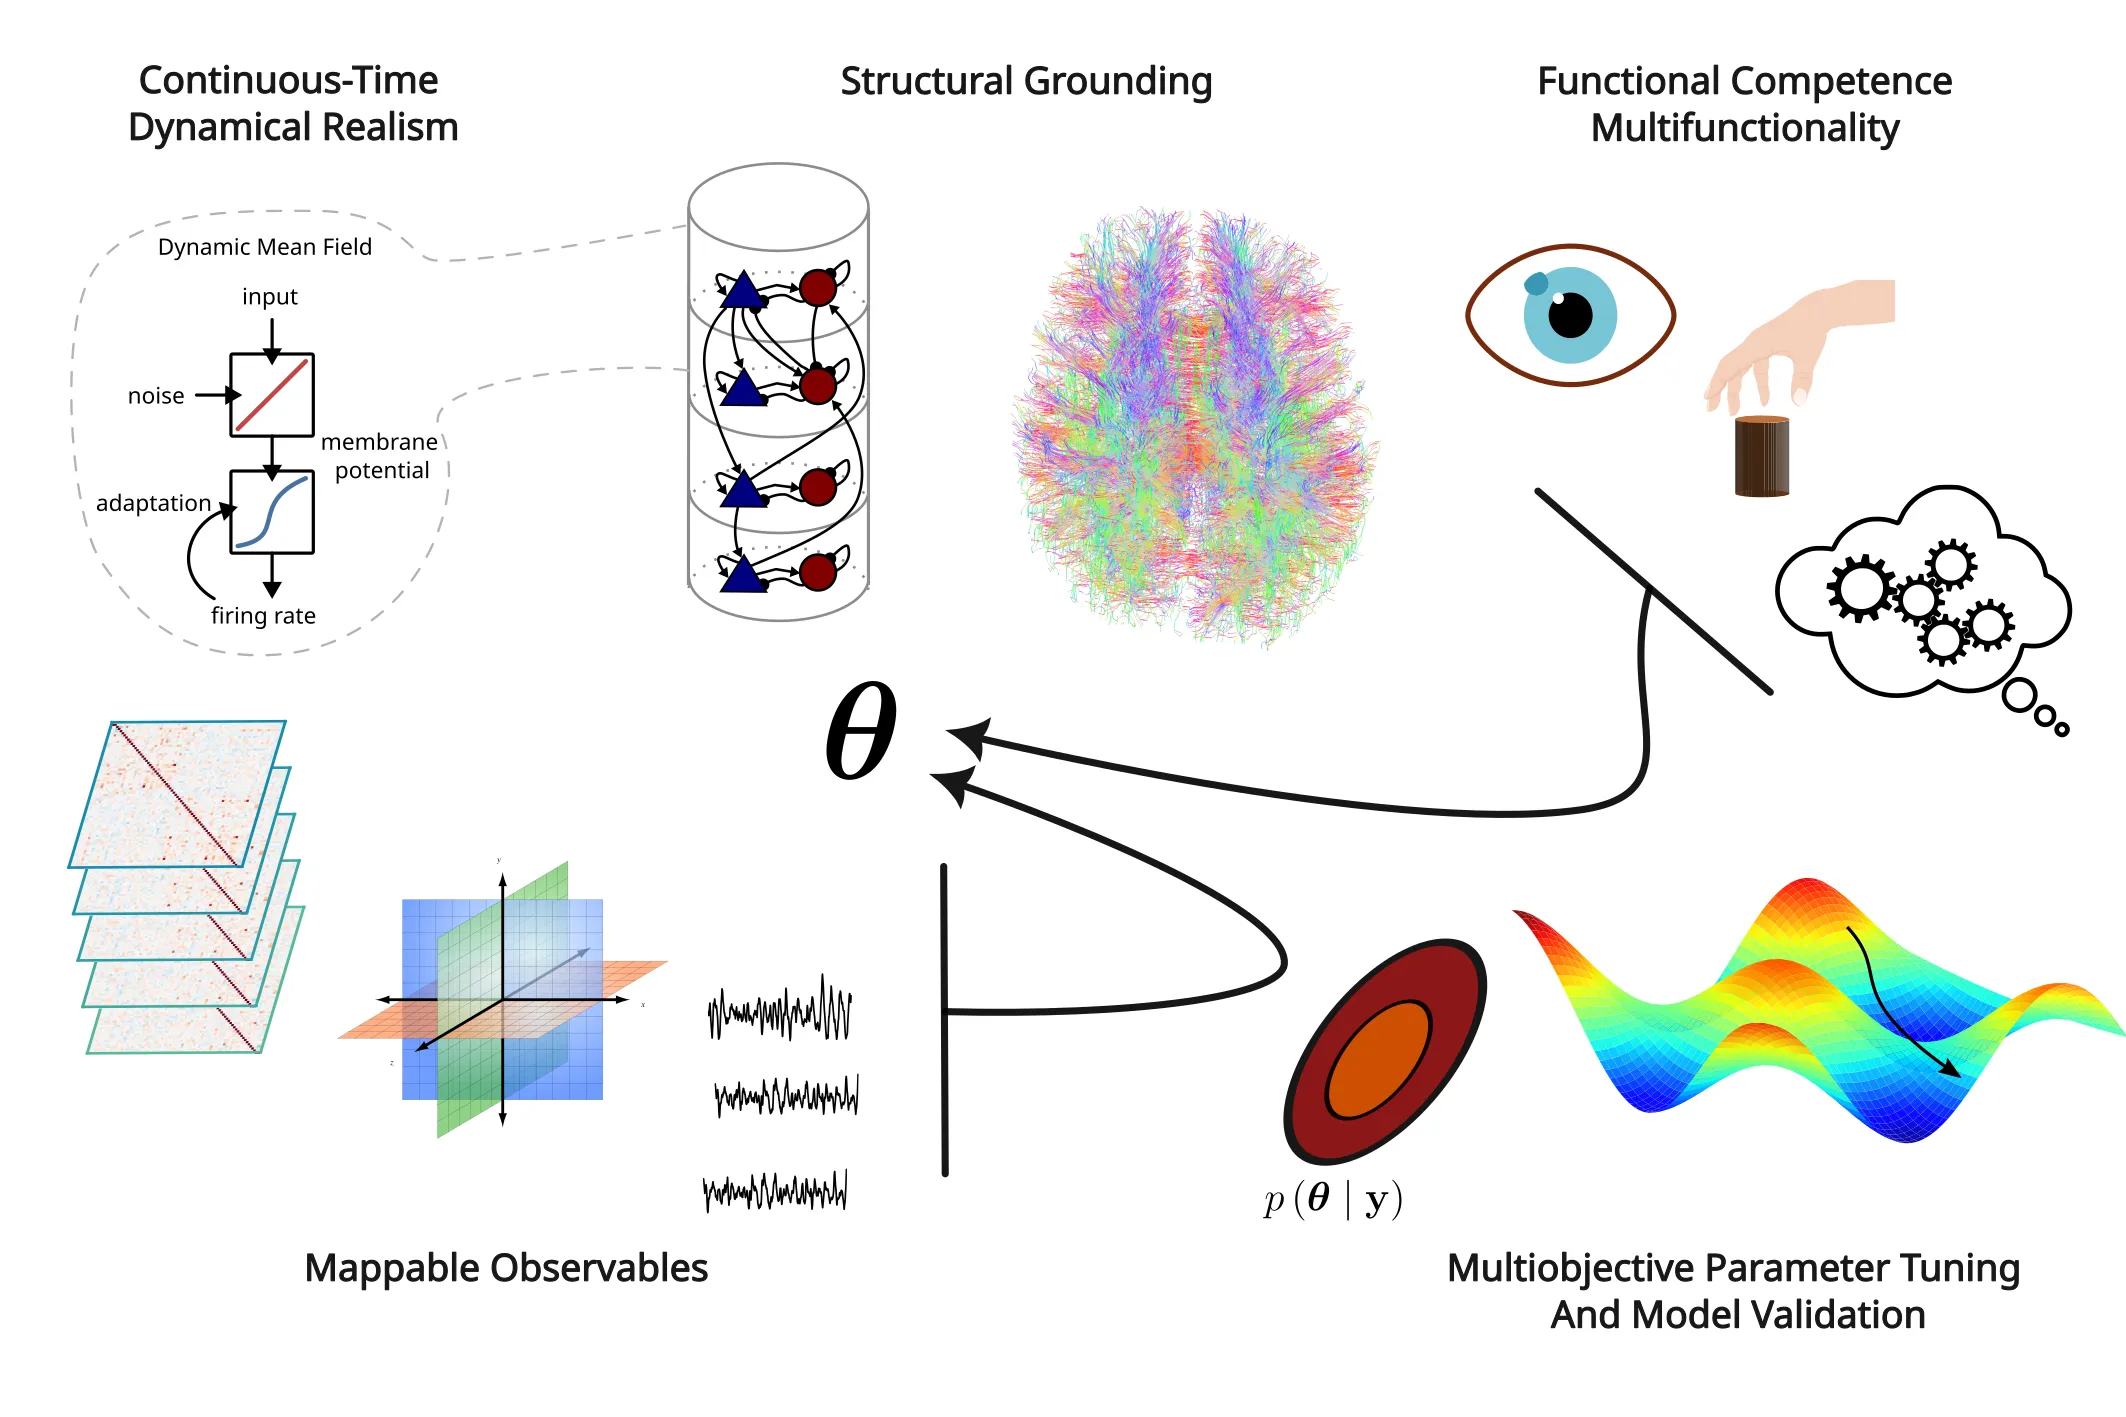
The functional whole-brain modelling paradigm. Five panels around a parameter vector theta show continuous-time dynamical realism, structural grounding, functional competence, mappable observables, and multi-objective parameter tuning with model validation.
The functional whole-brain modelling paradigm. Four minimal criteria define these models. Structural grounding derives the architecture from empirical structural connectivity and region-specific biological properties. Continuous-time dynamical realism describes local dynamics with differential equations, here a dynamic mean-field unit. Functional competence means the model processes ecologically valid inputs and generates overt and covert behaviour. Mappable observables make internal dynamics comparable to fMRI, EEG and LFP signals and to biological representations. Multi-objective parameter tuning fits the model. Bayesian inference sets biologically plausible starting points. Gradient-based optimization then refines the parameters towards task performance. From Senden et al. (2026), arXiv 2605.18118.

Building block

Laminar cortical columns

Our models use features of biological structure such as cortical layers and columns. In one such model, the layered structure of cortex explains reversal dynamics in bistable perception.
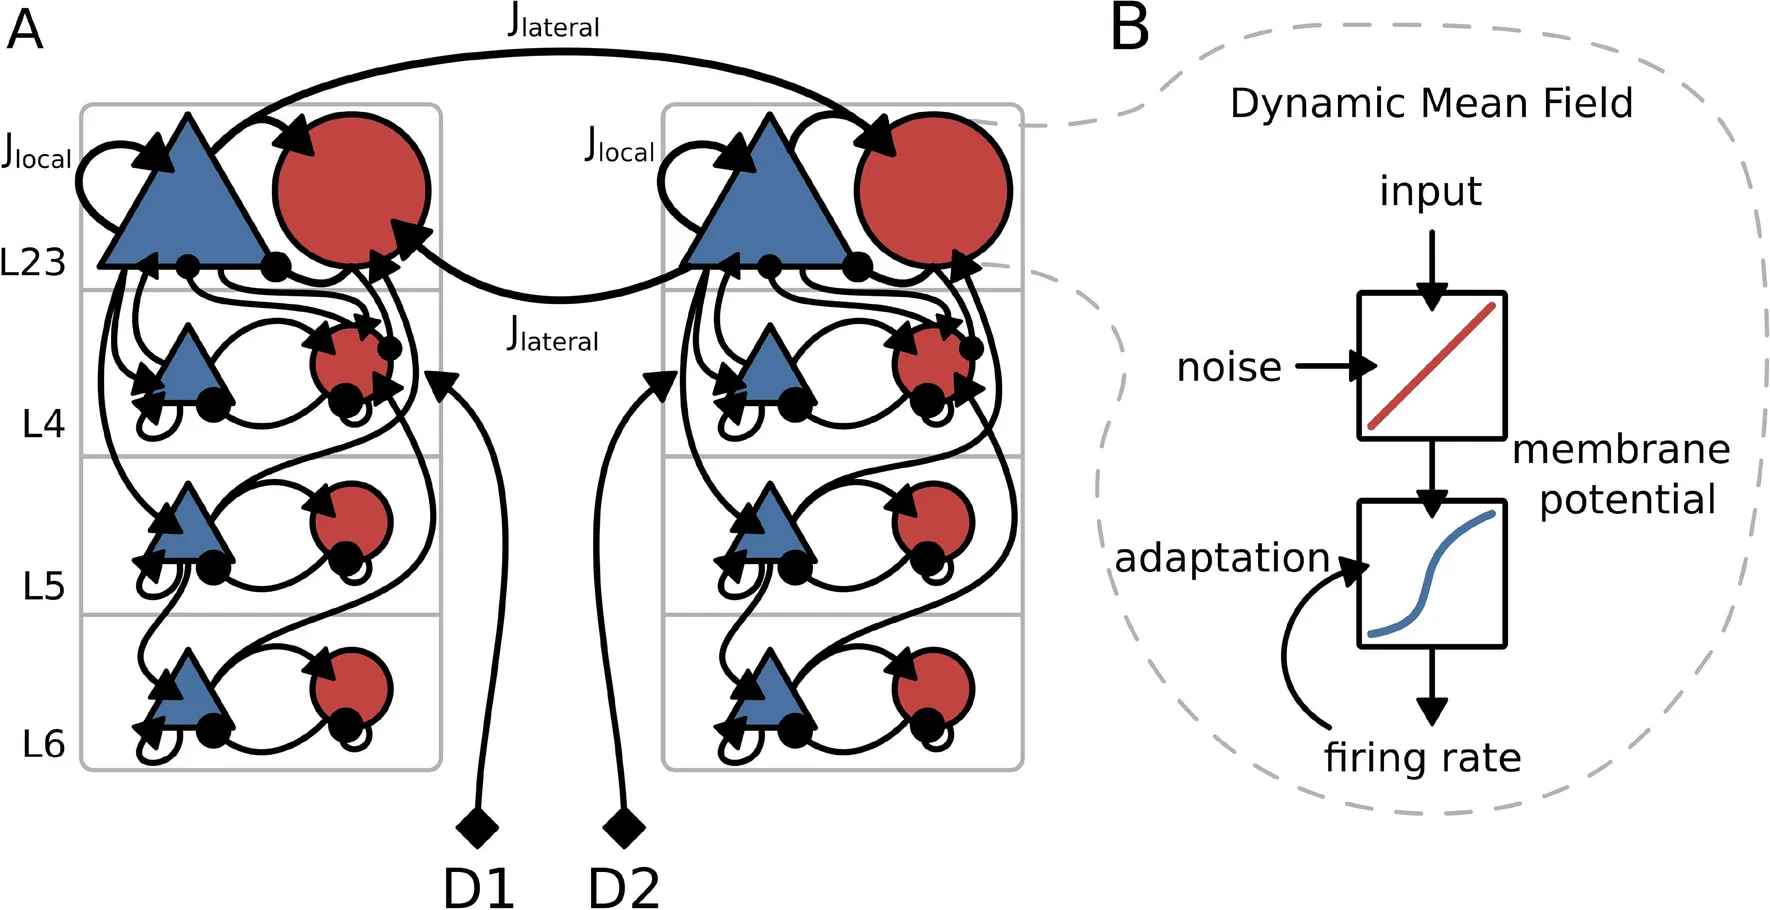
Diagram of the laminar column model. Two cortical columns with layers 2/3, 4, 5 and 6, excitatory and inhibitory populations, local and lateral connections, and inputs to layer 4.
Fig. 2 from Evers, K. S., Peters, J. C., Goebel, R., & Senden, M. (2025). Layered structure of cortex explains reversal dynamics in bistable perception. Scientific Reports, 15, 36878. doi:10.1038/s41598-025-20811-2. Licensed under CC BY-NC-ND 4.0.

Research line

Embodied, goal-driven brain models

We build embodied, goal-driven brain models of sensorimotor control. Our open-source toolkit AngoraPy supports this work. Other groups use it too.
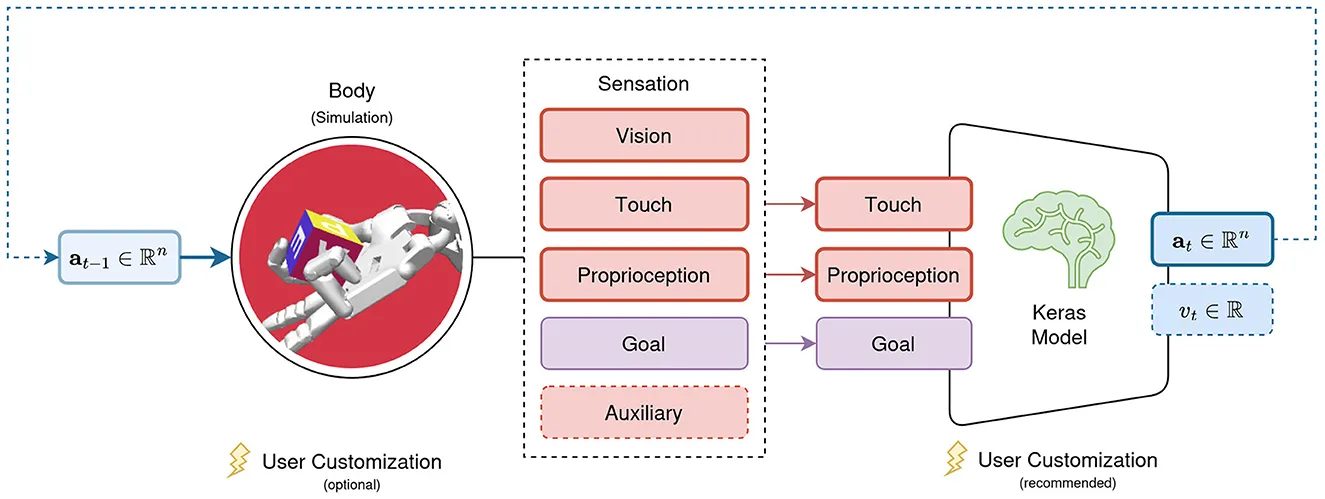
In-hand object manipulation with a simulated hand, trained in AngoraPy. From the AngoraPy repository (GPL-3.0).
AngoraPy model requirements. A body receives actions and returns vision, touch, proprioception, goal and auxiliary sensations to a Keras model, which outputs the next action and a value estimate.
Figure 3 from Weidler, T., Goebel, R., & Senden, M. (2023). AngoraPy: A Python toolkit for modeling anthropomorphic goal-driven sensorimotor systems. Frontiers in Neuroinformatics, 17, 1223687. doi:10.3389/fninf.2023.1223687. CC BY 4.0.

Open source

Software & data

  • Software

    AngoraPy

    An open-source library for building goal-driven embodied brain models. It trains deep neural network models of the brain on customizable sensorimotor tasks with reinforcement learning. It scales from a workstation to high-performance computing clusters.

    Licence GPL-3.0

    GitHubPaperPyPI

  • Software

    CNI Toolbox

    The Computational Neuroimaging Toolbox estimates input-referred models. It includes Fourier analyses of phase-encoded stimuli, population receptive field mapping and fast real-time population receptive field mapping.

    Licence LGPL-3.0

    GitHubZenodo

  • Data

    Figure-ground psychophysics dataset

    Human psychophysics data on figure-ground segregation in texture stimuli. It accompanies Karimian et al. in eLife.

    Licence CC BY 4.0

    Zenodo datasetPaper

  • Data

    NeuroScape

    A curated dataset of neuroscientific articles published between 1999 and 2023, with research domain clusters. The code repository holds the analyses behind The Evolving Landscape of Neuroscience.

    Licence CC BY 4.0 (data), MIT (code)

    Zenodo datasetGitHubPaper